Robotics
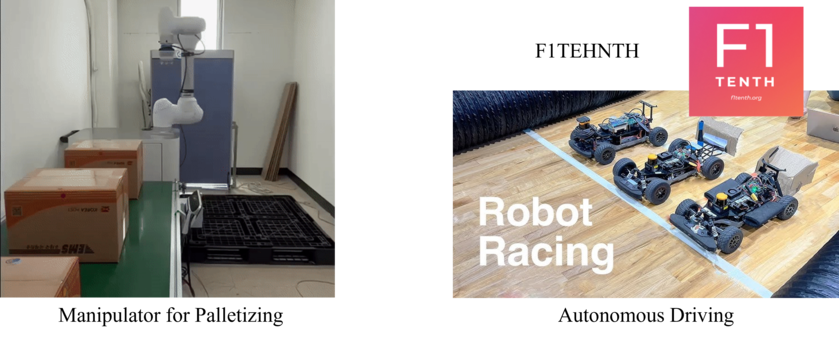
We bring our advances in reinforcement learning and computer vision onto real robotic systems, from mobile platforms to factory floors.
- Mobile Vehicles
- Autonomous Vehicle System
- Manipulators (Robot Arms)
- Manufacturing System
Deep Learning Vision
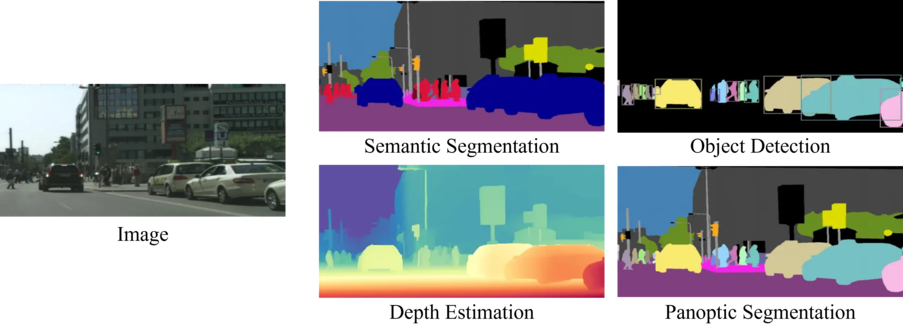
Perception
Reading the scene
Dense understanding of what is around the robot - what objects are there, where they are, and how far away.
- Semantic Segmentation
- Depth Estimation
- Object Detection
- Panoptic Segmentation
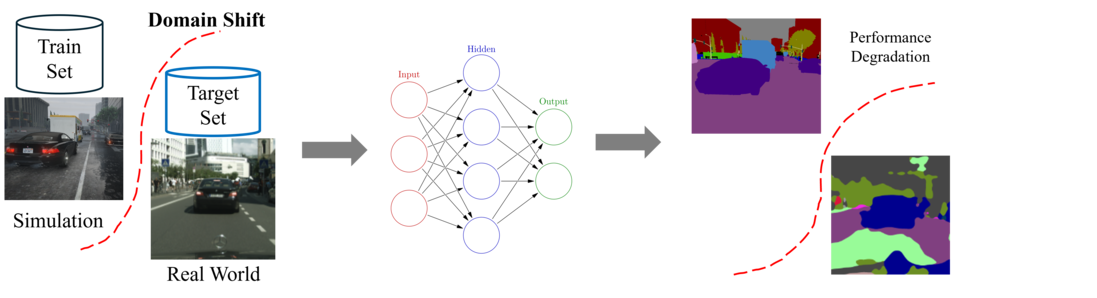
Robust Vision
Holding up outside the lab
Rain, night, fog and unfamiliar sites break models trained on clean data. We make perception survive that gap.
- Image Restoration
- Domain Adaptation
- Domain Generalization
Efficient Vision
Running on the robot itself
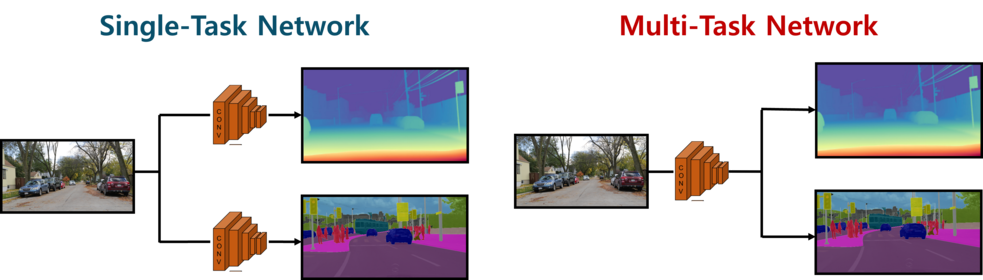
Robots carry limited compute. We keep accuracy while cutting the cost of running it.
- Multi-Task Learning
- Knowledge Distillation
Autonomous Driving
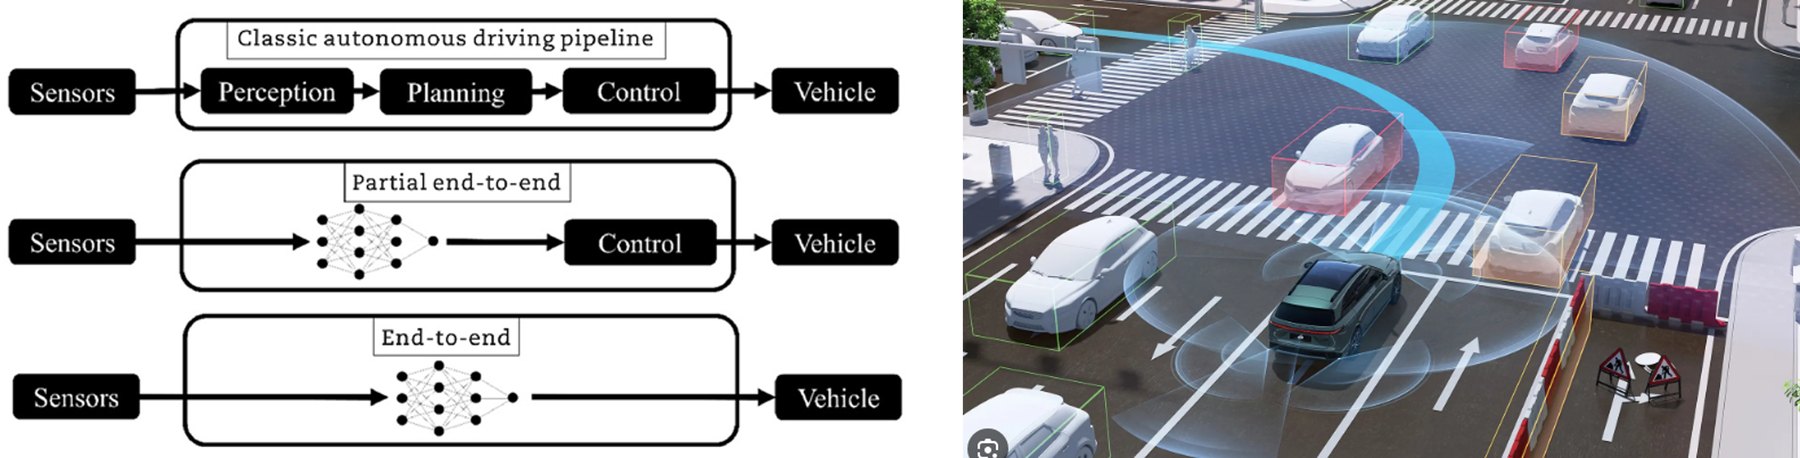
Instead of hand-wiring perception, planning and control into separate modules, we learn driving policies directly from multi-modal sensor input.
- End-to-End Policy Learning
- Safety-Aware Driving
- Multi-Modal Fusion (Camera / LiDAR / IMU)
- Sim-to-Real Transfer
Reinforcement Learning
Imitation Learning
Learning from demonstration
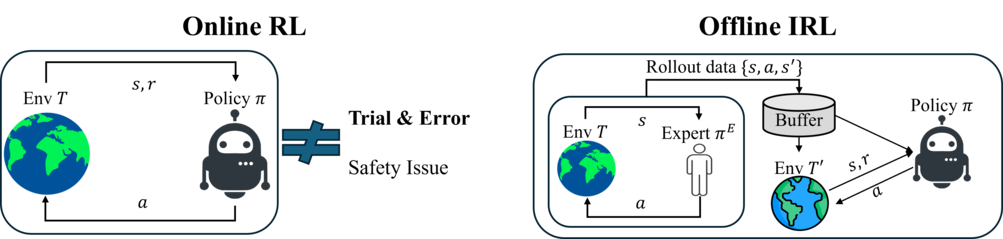
Agents that pick up expert behaviour from recorded human demonstrations instead of millions of trial-and-error episodes.
- Behavior Cloning
- Offline RL
- Inverse RL
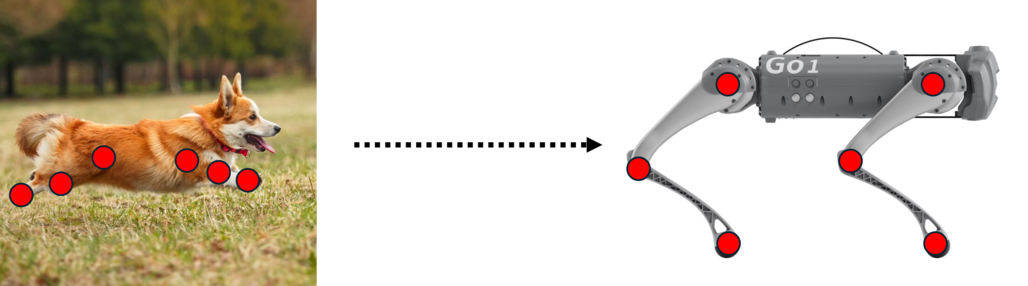
Embodied AI
Transferring across bodies
A policy learned on one robot should not be thrown away when the hardware changes.
- Cross Embodiment
- Domain Randomization
- Model Approximation